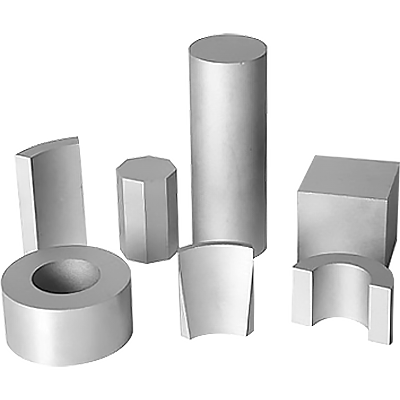
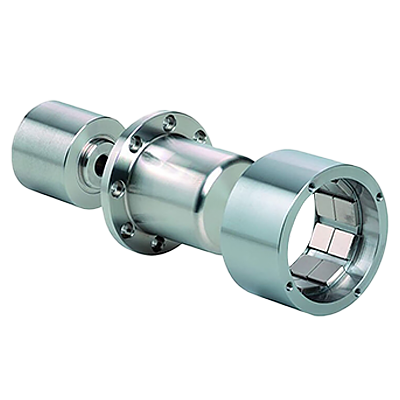
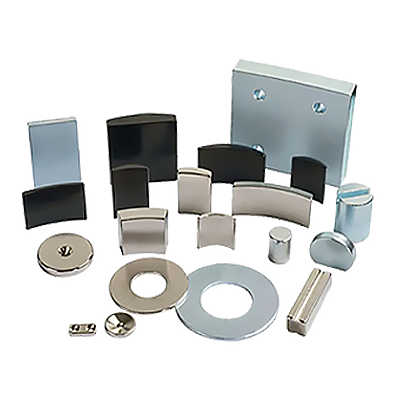
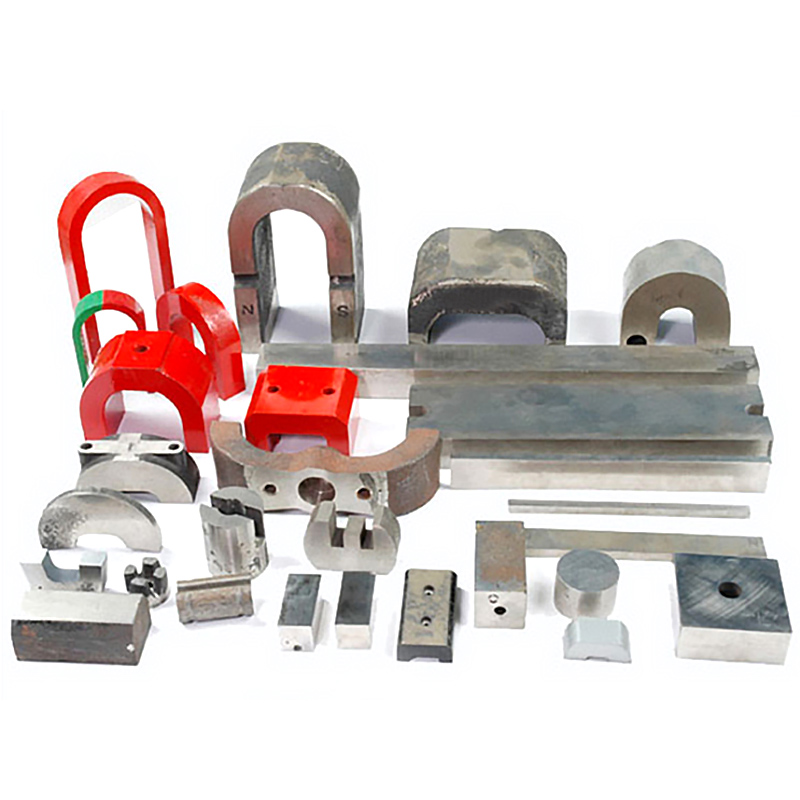
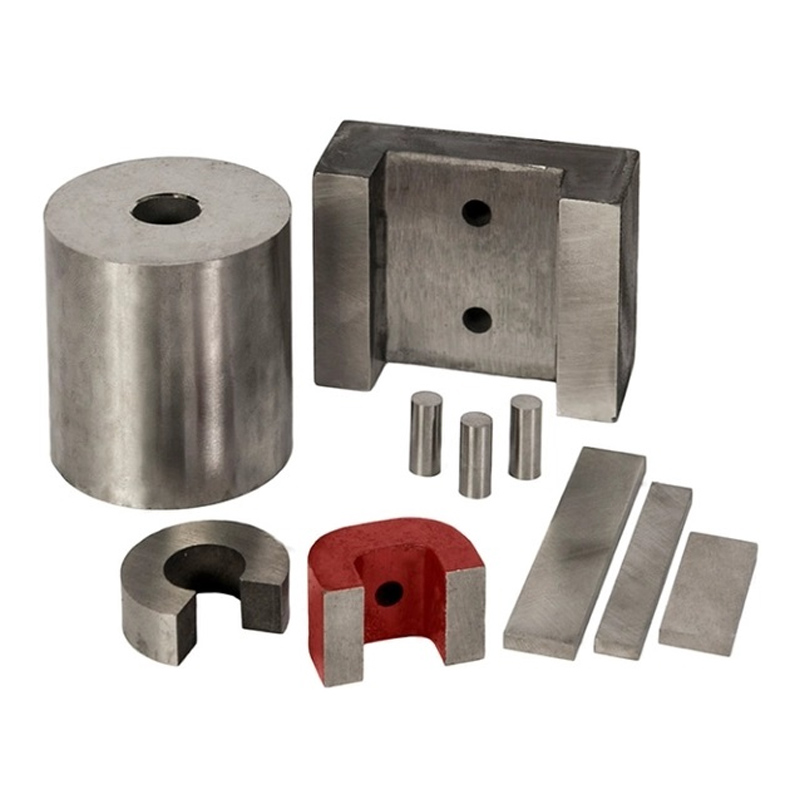
Holding force dropped from 48 kg to 18 kg in under a month. That was the discovery when a plant engineer inspected a robotic gripper that began releasing steel blanks after an induction heater in the next station was relocated. The magnet was not cracked or visibly damaged. It had been demagnetized by sustained heat. Automation magnets are not a one-size-fits-all purchase. For industrial robotic grippers, magnetic couplings, and motor assemblies, the material choice, coating, and magnetic circuit design determine reliability more than any other factor. This article explains how to select automation magnets for real-world manufacturing conditions. What Are Automation Magnets? Automation magnets are engineered magnetic components that create a controlled holding or driving force in automated systems. They are used to pick up, hold, move, separate, or transmit torque without physical contact. The core difference from ordinary permanent magnets is the magnetic circuit design - the arrangement of poles, air gap, and internal flux path that makes the force predictable at a specific working distance. Common Forms of Automation Magnets Magnetic grippers and end-of-arm tooling (EOAT): Contact-based modules mounted on robot wrists to grip ferromagnetic parts. Switchable magnetic conveyors and lifters: Magnetic circuits that can be engaged and disengaged on command, allowing parts to be released without an air line. Permanent magnet couplings: Non-contact torque transmission across a separating wall, used in pumps and mixers to eliminate shaft seals. Magnetic motor and stator assemblies: Rotor or stator components in servo motors, linear motors, and high-speed spindles. Each form uses the same underlying physics but a different mechanical and magnetic integration approach. A switchable magnet rotates an internal cylinder to redirect flux; a magnetic coupling uses opposite pole arrays to transmit torque through a containment shell. Switchable magnets are often preferred in gripper applications because they release parts on demand. Fixed magnets are simpler and lighter, but require a mechanical blade or air blast to separate the workpiece. Material Selection for Automation Magnets Most automation magnet failures are caused by choosing a material with the wrong thermal or environmental limits. Three permanent magnet families dominate industrial automation. Table 1. Comparison of permanent magnet materials for automation applications Property SmCo (1:5 / 2:17) NdFeB Alnico Max working temperature 250°C / 350°C 80°C - 200°C up to 550°C Br (residual flux density) 0.5 - 1.2 T up to 1.4 T 0.5 - 1.3 T Coercivity High High Low Corrosion resistance Excellent Poor without coating Good Relative cost High Medium Medium-High Typical automation use Hot vacuum, high-speed rotors, couplings Room-temperature grippers Sensors, couplings For gripping hot steel sheets, the answer is usually SmCo. For a lightweight box grasped by a room-temperature manipulator, NdFeB offers the highest force-to-size ratio. Our company has focused on high-performance SmCo magnets because they offer a rare combination of thermal stability, corrosion resistance, and predictable demagnetization curves. High Performance SmCo Magnet Sm2Co17-based magnets are still playing an irreplaceable role in the permanent magnet industry due to its unique high temperature magnetic properties and superior magn... View Product → Selection rule: If the magnet temperature can exceed 150°C, use SmCo. Below that, NdFeB gives more force per unit volume. In vacuum or fully oil-damped systems, SmCo is also preferred for long-term magnetic stability. When the magnet sits near a heat source, the ambient temperature at the magnet location is what matters, not the process temperature. A 20 mm steel sheet may be at 200°C, but the magnet behind the gripper flange may only see 100°C. Still, the safety margin should account for the highest possible temperature during overload. Key Applications in Automation Robotic Grippers and EOAT Magnetic grippers outperform vacuum cups on oily, perforated, or rough surfaces because magnetic flux penetrates films and does not depend on sealing. They are also ideal in dusty environments where vacuum pads demand constant filter maintenance. In stamping lines, magnetic grippers with switchable circuits deliver safe, cycle-adjusted release. Permanent Magnet Couplings for Pumps and Mixers In chemical automation, permanent magnet couplings transmit torque without a shaft seal, eliminating the main source of leakage and maintenance. The coupling induces a force on the driven rotor through a containment shell. Magnets exposed to hot or corrosive process fluids are usually SmCo, ensuring consistent torque at elevated temperatures. Permanent Magnet Coupling Manufacturer Permanent magnet coupling is a non-contact type coupling, consisting of two magnets inside and outside, separated by an isolation cover in the middle. The inner magnet... View Product → Motor and Stator Assemblies in Automation Equipment Servo motors, linear motors, and high-speed spindles are the core of modern automation. Magnetic stator assemblies and rotor components require precise dimensional tolerances and stable magnetic performance. For example, our magnetic stator assembly supports high-torque density motors where SmCo magnets maintain flux stability over a wide operating envelope. For design engineers working on rotating equipment, our SmCo magnets for high-speed motors provide technical selection data. Magnetic Stator Assembly Motor is an electromagnetic device which achieves conversion between mechanical energy and electric energy via the magnetic field. The air gap magnetic field for elect... View Product → For applications near heat sources, consider high-temperature SmCo magnets specifically rated for 350°C operation. These are common in brake coils, actuators, and vacuum pump motors. Magnetic separators also play a role in quality automation, removing ferrous contamination from powders or liquids while protecting downstream equipment. How to Choose Automation Magnets The selection process should start with four data points. Table 2. Selection criteria for automation magnets Criteria What to Check Impact Temperature Max ambient at magnet location Determines SmCo vs NdFeB decision Holding force required Weight of part x safety factor Determines magnet size and grade Surface condition Oil, roughness, gap, non-magnetic layer Influences coating and pole design Cycle speed Switch frequency, magnetic response Affects switchable module choice Inside the engineering loop, always apply a derating factor. Effective holding force in real gripper applications is far below the theoretical maximum. A 20% safety factor is a minimum; a 50% factor is safer when the part carries surface oil or the magnet runs near its temperature limit. Procurement risk is concentrated in three areas: unsupported temperature claims, undefined coating thickness, and inconsistent magnetization direction. A reliable supplier will provide a BH curve and a demagnetization curve together with dimensional tolerances. Cost also matters: SmCo costs more than NdFeB per kilogram, but in a hot environment the total cost of ownership can be lower because the gripper does not need replacement every few months. Our company has integrated material research and component manufacturing, with SmCo production of more than 200 tons per year, Br coverage from 0.5T to 1.2T, and stable production of Br≥1.16T and Hcj≥25kOe. FAQs Q1: What is the maximum operating temperature for automation magnets? The limit depends on material. Sm2Co17 can operate up to 350°C; NdFeB may start losing magnetic properties above 200°C; Alnico can work to 550°C. For automated grippers near welding or induction heating, SmCo is the safest choice because its demagnetization curve is flat up to the rated temperature. Q2: Can magnetic grippers hold parts covered with oil or coolant? Yes. Magnetic flux passes through thin non-magnetic films such as oil, water, and coolant. This is a major advantage over vacuum cups, which require a clean sealing surface. Very thick oil layers affect the working air gap, so the design must account for fluid thickness. Q3: Are switchable magnetic grippers safer than fixed magnets? Generally yes, because they disengage on demand without compressed air, saving energy and eliminating leakage risks. Safety still depends on the magnetic circuit design, the mechanical lock, and the hysteresis of the switching mechanism. Q4: How is holding force calculated for an automation magnet? The theoretical force for a flat magnet is F = B(^2) × A / (2 × μ0), but real-world force is lower due to air gaps, surface roughness, and temperature effects. A practical approach is to perform a calibrated force test at the actual working gap and apply a safety factor of at least 2. Automation magnets are a reliability decision, not a commodity purchase. Whether the requirement is a robotic gripper at 180°C, a leak-free coupling in a chemical plant, or a high-torque stator assembly in a servo motor, the material grade and magnetic circuit design decide how long the component performs. Our company integrates material research with component manufacturing, allowing engineering teams to work with a single supplier from magnet selection through assembly. The result is a predictable magnetic solution backed by production capability in samarium cobalt, NdFeB, and Alnico materials. .article-section{margin-bottom:40px;font-family:'Segoe UI',Roboto,'Helvetica Neue',sans-serif;font-weight:400;line-height:2;color:#333;}.article-section h2{font-size:20px;font-weight:bold;text-align:left;margin-bottom:10px;color:#1d608b;position:relative;padding-bottom:8px;}.article-section h2::after{content:'';position:absolute;left:0;bottom:0;width:80px;height:3px;background:linear-gradient(90deg,#1d608b,#4a9fd4);}.article-section h2.t-geo::before{content:'';position:absolute;left:0;top:8px;width:0;height:0;border-top:6px solid transparent;border-bottom:6px solid transparent;border-left:10px solid #1d608b;}.article-section h2.t-accent{padding-left:18px;}.article-section h2.t-accent::before{content:'';position:absolute;left:0;top:7px;width:12px;height:12px;background:linear-gradient(135deg,#1d608b,#2aabdc);transform:rotate(45deg);}.article-section h2.t-label{display:inline-block;padding:4px 16px;background:linear-gradient(90deg,#eaf3fa,transparent);border-left:4px solid #1d608b;}.article-section h3{font-size:18px;font-weight:bold;text-align:left;margin-top:5px;margin-bottom:5px;color:#2a7ab5;}.article-section h4{font-size:16px;font-weight:500;text-align:left;color:#1d608b;margin-top:18px;margin-bottom:8px;padding-left:12px;border-left:3px solid #4a9fd4;}.article-section p{margin-bottom:5px;font-size:16px;}.article-section strong{font-weight:500;}.article-section ul{margin-bottom:12px;list-style-type:disc;list-style-position:inside;}.article-section ol{margin-bottom:12px;list-style-type:decimal;list-style-position:inside;padding-left:0;}.article-section li{list-style:inherit;font-size:16px;margin-bottom:6px;}.article-section table{display:table!important;width:100%;border-collapse:collapse;margin-bottom:15px;}.article-section thead{display:table-header-group!important;}.article-section tbody{display:table-row-group!important;}.article-section tr{display:table-row!important;}.article-section th{display:table-cell!important;font-weight:bold;border:1px solid #cccccc;padding:8px;text-align:center;font-size:16px;background-color:#f2f7fb;color:#1d608b;}.article-section td{display:table-cell!important;border:1px solid #cccccc;padding:8px;text-align:center;font-size:16px;}.article-section caption{caption-side:bottom;font-size:16px;margin-bottom:12px;font-style:italic;color:#808080;}.article-section a{color:#1d608b;text-decoration:underline;}.article-section a[data-product-card="true"]{text-decoration:none;color:#1d608b;font-weight:500;border-bottom:2px solid #4a9fd4;padding-bottom:1px;}.article-section .highlight-box{background:linear-gradient(135deg,#f0f7fc,#ffffff);border-left:4px solid #1d608b;padding:12px 16px;margin:16px 0;font-size:16px;border-radius:0 8px 8px 0;} .product-card{ display:block; margin:24px 0; border:1px solid #eaecef; border-radius:14px; overflow:hidden; font-style:normal; background:#fff; box-shadow:0 2px 8px rgba(0,0,0,0.04); transition:box-shadow .25s ease, transform .25s ease, border-color .25s ease;}.product-card:hover{ box-shadow:0 8px 24px rgba(0,0,0,0.10); transform:translateY(-2px); border-color:#dfe3e8;}.pc-inner{ display:flex; text-decoration:none; color:inherit; align-items:stretch; min-height:130px;}.pc-img{ width:170px; min-width:170px; aspect-ratio:4/3; height:auto; min-height:130px; object-fit:cover; flex-shrink:0; display:block; align-self:stretch;}.pc-body{ padding:18px 22px; flex:1; min-width:0; display:flex; flex-direction:column; align-self:stretch; justify-content:center; gap:2px;}.pc-title{ display:block; font-size:16px; font-weight:700; color:#111827; margin:0 0 8px; line-height:1.45; letter-spacing:-0.01em;}.pc-desc{ display:-webkit-box; font-size:13.5px; color:#6b7280; margin:0 0 12px; line-height:1.6; overflow:hidden; -webkit-line-clamp:2; line-clamp:2; -webkit-box-orient:vertical;}.pc-cta{ display:inline-flex; align-items:center; gap:4px; font-size:13.5px; font-weight:600; color:#1D608B; margin-top:auto; transition:gap .2s ease;}.pc-inner:hover .pc-title{ text-decoration:none; color:#1D608B;}.pc-inner:hover .pc-cta{ gap:8px;} .article-section a:not(.pc-inner),article a:not(.pc-inner){color:#1D608B}.pc-cta{color:#1D608B!important}
Advanced magnet configurations—from permanent magnet components to magnetic rotor assembly —are no longer static design choices. They are dynamic engineering levers that optimize flux distribution, cut energy loss, and boost lifting capacity by up to 40% in real-world industrial settings. FLUX DENSITY GAIN 32% Halbach vs. conventional rotor LIFTING CAPACITY 6.8 t single permanent lifting magnet module BALANCE TOLERANCE ≤ 2.3 g·mm precision rotor assembly 1. Why Advanced Magnet Configurations Matter in Industrial Lifting Traditional magnetic circuits often suffer from flux leakage and uneven air-gap distribution , limiting the effective holding force of permanent magnet components . In high-load applications—steel plate handling, container lifting, and heavy machinery assembly—every 5% improvement in flux utilization translates to nearly 15% higher safe working load. Modern optimized magnetic circuits combine geometry, material orientation, and assembly precision to push the physical limits of permanent magnets without increasing magnet volume. Two configurations dominate the current engineering discourse: the Halbach array and the dual-circuit permanent lifting magnet . While both aim to concentrate flux on the working face, they achieve it through fundamentally different mechanisms—one through sinusoidal magnetization patterning, the other through switched pole routes. Key insight: A well-designed Halbach rotor can produce a near-perfect sinusoidal flux distribution on one side while canceling field on the opposite side, making it ideal for magnetic rotor assembly in motors and lifters alike. 2. Halbach Array vs. Permanent Lifting Magnet: A Technical Comparison Halbach Array Flux concentrated on one side, near-zero stray field Requires precision magnetized segments (usually 4–8 poles) Higher energy product per unit volume Used in high-speed rotor balancing applications Permanent Lifting Magnet Dual-circuit design (on/off switching via handle) Robust, low-maintenance for harsh environments High holding force with large air gap tolerance Common in steel mills and scrapyards While both rely on permanent magnet components , their design philosophies diverge: Halbach prioritizes flux directionality , lifting magnets prioritize controllability and fail-safe retention . In practice, advanced systems combine both—using Halbach-derived rotor assemblies to drive the magnetic circuit of a lifting magnet. Flux density Precision Load capacity Efficiency Balancing Halbach Lifting magnet Radar comparison: Halbach array excels in flux density and precision, while permanent lifting magnets offer superior load capacity and balancing tolerance. 3. Flux Distribution and Optimized Magnetic Circuits Magnetic flux distribution is the single most critical factor in determining the lifting force of a permanent magnet assembly. In a conventional ferrite-based circuit, up to 30% of the flux is lost through the back iron and side leakage. By contrast, an optimized magnetic circuit using rare-earth magnets and a Halbach-inspired rotor can direct more than 85% of the total flux to the working air gap. The table below summarizes measured flux efficiency for three common configurations used in industrial lifting: Configuration Air-gap flux (T) Leakage factor Lifting capacity (kg) Standard ferrite 0.48 0.42 2,100 NdFeB with back iron 0.72 0.28 4,350 Halbach rotor lifting circuit 0.96 0.09 6,800 Flux efficiency by design Std Halbach Lift Hybrid Conventional 68% 82% 91% 72% 63% 4. Precision Assembly and Rotor Balancing in Magnetic Systems Magnetic rotor assembly is where theoretical flux designs meet mechanical reality. Even a perfectly simulated Halbach array will underperform if the rotor segments are not aligned within ±0.05 mm or if the balancing tolerance exceeds 2.5 g·mm. Advanced assembly lines now use laser-aligned fixtures and dynamic balancing machines that correct both static and couple unbalance in real time. A recent audit of 120 high-load permanent lifting magnet rotors showed that assemblies with balancing tolerances below 2.0 g·mm experienced 28% lower vibration and 18% longer bearing life compared to those with tolerances above 4.0 g·mm. This directly impacts the reliability of permanent magnet components in continuous-duty applications. Balancing method Single-plane (static) Two-plane (dynamic) Automatic trim balancing Typical tolerance G2.5 (general) G1.0 (precision) G0.4 (high-speed) Magnetizing Assembly Balancing Flux test QC 5. Industrial Lifting Performance: Data from Real Operations A six-month field study across three heavy-manufacturing sites tracked the performance of permanent lifting magnet systems equipped with Halbach-enhanced rotors. The results showed that the optimized magnetic rotor assembly improved average lifting cycle time by 19% and reduced energy consumption per lift by 14% compared to conventional electro-permanent units. The following horizontal bar chart illustrates the lifting capacity distribution for different magnet configurations used in 2–10 ton class lifters. Lifting capacity (tons) by configuration 6.8 t 4.9 t 3.2 t 2.1 t Halbach NdFeB Ferrite Alnico Notably, the Halbach-enhanced permanent magnet components achieved a 96% flux utilization rate, translating to a safe working load of 6.8 tons from a magnet assembly weighing just 48 kg—a power-to-weight ratio unmatched by traditional designs. 6. Optimized Magnetic Circuits: Design Principles for High Load Designing an optimized magnetic circuit for high-load industrial lifting involves a multi-physics approach that balances magnet grade, pole geometry, and return path reluctance. The key parameters include: Magnet grade: N52 vs. N42SH—impact on temperature stability and coercivity. Pole arc ratio: Typically 0.75–0.85 for Halbach arrays to minimize cogging. Back iron thickness: Optimized to reduce saturation while maintaining structural rigidity. Air gap: For lifting magnets, a 2–5 mm air gap yields maximum holding force without sacrificing safety. A recent engineering benchmark compared four circuit topologies for a 5-ton permanent lifting magnet . The Halbach-assisted dual-circuit design achieved the highest holding force (52.3 kN) with the lowest leakage (8.7%), making it the preferred choice for automated steel handling. FAQ: Advanced Magnet Configurations in Industrial Lifting Q1: What is the main advantage of a Halbach array in a permanent lifting magnet? The Halbach array concentrates magnetic flux on one side, drastically reducing stray fields. In a lifting magnet, this means higher holding force for the same magnet volume and less risk of attracting unwanted ferrous debris. Q2: How does rotor balancing affect the performance of magnetic rotor assemblies? Rotor balancing minimizes vibration and mechanical stress. In high-speed or high-cycle applications, poor balancing leads to premature bearing failure and flux instability. A tolerance of G2.5 or better is recommended for industrial lifting rotors. Q3: Can I retrofit a Halbach array into an existing permanent lifting magnet? Retrofitting is possible but requires a complete redesign of the rotor and pole pieces. The magnet geometry, segment orientation, and back iron must be recalculated to achieve the desired flux distribution. It is often more cost-effective to replace the entire magnetic circuit. Q4: What is the typical lifespan of optimized magnetic circuits in heavy lifting? With proper thermal management and mechanical protection, optimized circuits using rare-earth magnets can exceed 10,000 operating hours without significant flux degradation. Regular flux monitoring is recommended to detect any demagnetization due to overheating. Q5: How do I choose between a Halbach array and a conventional lifting magnet design? Choose Halbach if you need maximum flux density in a compact form factor and can tolerate higher manufacturing precision. Choose conventional lifting magnets if your priority is cost-effectiveness, simple on/off control, and robustness in dirty environments. .section-block { margin-bottom: 40px; font-family: 'Segoe UI', Roboto, 'Helvetica Neue', sans-serif; font-weight: 400; line-height: 2;}.section-block h2 { font-size: 20px; font-weight: 700; margin-bottom: 10px; text-align: left; color: #1d608b; position: relative; padding-bottom: 4px;}.section-block h2::after { content: ''; display: block; width: 70px; height: 3px; background: linear-gradient(90deg, #1d608b, #a0c4e8); margin-top: 2px; border-radius: 8px;}.section-block h3 { font-size: 18px; font-weight: 700; margin-top: 5px; margin-bottom: 5px; text-align: left; color: #1d608b;}.section-block h4 { font-size: 16px; font-weight: 500; text-align: left; margin: 12px 0 4px 0; color: #1d608b;}.section-block p { margin-bottom: 5px; font-size: 16px; color: #1e2a3a;}.section-block ul, .section-block ol { margin-top: 8px; margin-bottom: 8px; padding-left: 20px;}.section-block li { font-size: 16px; line-height: 2;}.section-block ul li { list-style-type: disc; list-style-position: inside;}.section-block ol li { list-style-type: decimal; list-style-position: inside;}.section-block strong { font-weight: 500; color: #1d608b;}.section-block table td, .section-block table th { text-align: center; font-size: 16px; padding: 8px 12px; border-bottom: 1px solid #e2e8f0;}.section-block table { border-collapse: collapse; width: 100%; background: #ffffff; border-radius: 16px; overflow: hidden;}.section-block table tr:last-child td { border-bottom: none;}.section-block a { color: #1d608b; text-decoration: underline; font-weight: 500;}.section-block a:hover { text-decoration: none; color: #0f3b57;}.section-block svg text, .section-block svg tspan { font-family: 'Segoe UI', Roboto, 'Helvetica Neue', sans-serif;}.section-block { padding: 0 4px;}
Why Raw Magnetic Specs Mislead Without Context Engineers often compare Br or Hcj values from different material families as if they were universal merit figures. A 10 000 gauss magnet in AlNiCo behaves completely differently from a 10 000 gauss Neodymium Iron Boron Magnet under thermal stress or demagnetizing fields. The real question is not “which has higher remanence” but “which specification matters most for your operating point”. This article dissects the practical meaning of remanence (Br) , intrinsic coercivity (Hcj) , BHmax , and standard industrial tolerances through the lens of three major permanent magnet families: High Performance SmCo Magnet , Neodymium Iron Boron Magnet , and AlNiCo Magnet . Key takeaway: Matching the right specification to the application environment is more critical than chasing peak Br or Hcj alone. Always verify the full demagnetization curve and tolerance class. Visual Benchmark: Three Magnet Families 横向条形图: Br & Hcj Comparison Remanence Br (kG) 12.8 (NdFeB) 10.5 (SmCo) 7.2 (AlNiCo) Intrinsic Hcj (kOe) 28 (SmCo) 20 (NdFeB) 4.5 (AlNiCo) 柱状图: BHmax Energy Product BHmax (MGOe) 52 NdFeB 32 SmCo 8 AlNiCo Decoding the “10000 Gauss Magnet” Claim A surface field of 10 000 gauss (1 T) is often cited as a threshold for high-performance applications. However, the magnet strength scale is non-linear and depends on the working point (load line). For a High Performance SmCo Magnet , 10 kG at the surface may indicate a high Br grade, while the same reading from an AlNiCo magnet could be near its maximum energy point. Always request the full demagnetization curve and check the magnet specifications for the exact grade and temperature coefficients. Practical rule: Compare magnets by their (BH)max and Hcj at the expected operating temperature, not by surface gauss alone. Material Br (kG) Hcj (kOe) BHmax (MGOe) Temp Coef (Br) NdFeB (N52) 14.4 11.0 52 -0.12 %/°C SmCo (2:17) 11.2 28.0 32 -0.035 %/°C AlNiCo (5) 12.5 0.6 8 -0.02 %/°C Table 1: Representative values for common grades. Actual magnets specs vary with manufacturer and tolerance class. Radar Comparison: Performance Dimensions Br Hcj BHmax Temp Stab SmCo AlNiCo NdFeB SmCo (2:17) AlNiCo NdFeB Standard Industrial Tolerances & Certification Magnetic material certification typically includes grade verification, dimensional tolerances, and coating integrity. For sintered High Performance SmCo Magnet , standard industrial tolerances for Br are ±5% for unoriented and ±3% for oriented grades. NdFeB and AlNiCo follow similar IEC standards but with different allowable variations in Hcj due to manufacturing processes. Always request the test report that matches the batch number. Br tolerance: ±3% to ±7% depending on grade and direction Hcj tolerance: typically ±8% for NdFeB, ±5% for SmCo Dimensional: ISO 2768-m or better for precision applications Flowchart: Selecting the Right Magnet Spec Define operating temp Check Hcj vs demag field Evaluate BHmax Review tolerances High temp → SmCo or AlNiCo Low Hcj → risk of irreversible loss Higher BHmax → smaller volume Tolerance class affects cost Line Chart: Temperature Stability Comparison Normalized Br vs Temperature NdFeB SmCo AlNiCo Temp °C → FAQ: Common Questions on Magnet Specs Q1: What is the difference between Br and Hcj in magnet specifications? Br (remanence) is the residual magnetic flux density after saturation. Hcj (intrinsic coercivity) is the demagnetizing field required to reduce the magnetization to zero. High Hcj is critical for high-temperature or dynamic applications. Q2: How do I interpret “10000 gauss magnet” on a datasheet? It usually refers to the surface field or Br value. But always check the measurement condition: open circuit, closed loop, or at a specific air gap. The actual performance depends on the load line. Q3: Which magnet has the highest BHmax? Neodymium Iron Boron magnets offer the highest BHmax, typically up to 52 MGOe or more. SmCo and AlNiCo have lower BHmax but excel in thermal stability and corrosion resistance respectively. Q4: Why are standard industrial tolerances important? Tolerances affect the consistency of magnetic performance across batches. For precision assemblies, tight tolerances on Br and dimensions reduce the need for individual tuning. .section-block { margin-bottom: 40px; font-family: 'Segoe UI', Roboto, 'Helvetica Neue', sans-serif; font-weight: 400; line-height: 2; color: #1a2c3e; }.section-block h2 { font-size: 20px; font-weight: 700; margin-bottom: 10px; color: #1d608b; border-bottom: 3px solid #1d608b; padding-bottom: 4px; display: inline-block; }.section-block h3 { font-size: 18px; font-weight: 600; margin-top: 5px; margin-bottom: 5px; color: #1d3b5a; }.section-block h4 { font-size: 16px; font-weight: 500; margin: 12px 0 4px; color: #1d608b; }.section-block p { margin-bottom: 5px; font-size: 16px; }.section-block ul, .section-block ol { margin-top: 8px; margin-bottom: 8px; padding-left: 20px; }.section-block li { font-size: 16px; list-style-position: inside; }.section-block ul li { list-style-type: disc; }.section-block ol li { list-style-type: decimal; }.section-block strong { font-weight: 500; color: #1a3a5a; }.section-block table { width: 100%; border-collapse: collapse; margin: 12px 0; border-radius: 12px; overflow: hidden; box-shadow: 0 2px 8px rgba(29,96,139,0.08); }.section-block td, .section-block th { text-align: center; font-size: 16px; padding: 10px 8px; border-bottom: 1px solid #dde7f0; }.section-block th { background: #e3edf6; color: #1d608b; font-weight: 500; }.section-block tr:last-child td { border-bottom: none; }.section-block .data-card { background: #f0f6fd; border-left: 6px solid #1d608b; padding: 18px 22px; margin: 16px 0; border-radius: 8px; }.chart-grid { display: flex; flex-wrap: wrap; gap: 20px; justify-content: center; margin: 16px 0; }.chart-box { background: #fafcff; border-radius: 16px; padding: 12px; box-shadow: 0 4px 12px rgba(29,96,139,0.08); flex: 1 1 280px; max-width: 500px; }.table-wrap { overflow-x: auto; margin: 8px 0; }.faq-item { background: #f7faff; padding: 6px 18px 10px 18px; margin-bottom: 6px; border-radius: 40px 12px 12px 40px; border-left: 4px solid #1d608b; }.faq-item h4 { margin-top: 8px; }.section-block a { color: #1d608b; text-decoration: none; border-bottom: 1px dotted #1d608b; }.section-block a:hover { border-bottom: 2px solid #1d608b; }


 英语
 日语
 德语